
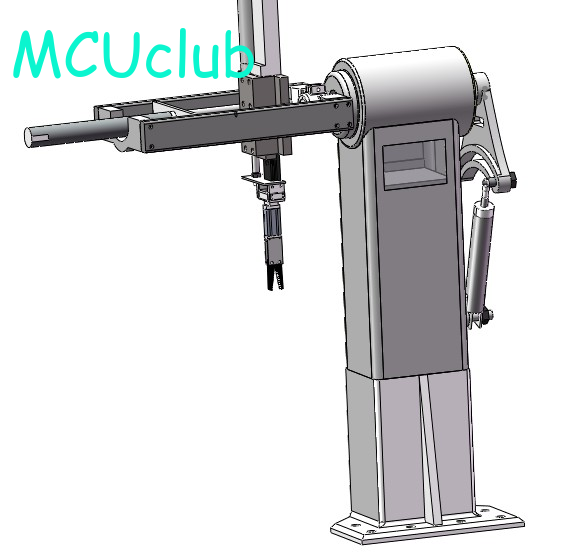
三维总装设计图
2D3D源文件
参考论文
针对数控滚齿机传统人工取料模式存在的生产效率低下、作业安全性不足及劳动强度大等痛点,本文开展数控滚齿机上下料机械手的设计研究。论文系统梳理了机械手的发展历程与工业应用场景,明晰其基本组成与核心设计内容;通过对机械手整体结构进行方案论证与优化设计,确定了适配滚齿机取料工况的坐标形式、自由度配置,完成手部夹持机构、手腕回转机构、主副臂伸缩机构及机身回转机构的方案规划,同时选定气动驱动方式与相应控制方案,明确机械手主要技术参数并分析其运动逻辑。在此基础上,对机械手各关键部件进行精细化结构设计与三维建模,通过理论计算完成手部夹持力、手腕及臂部驱动力矩的校核,合理选型气动元件,设计各部件间的连接结构与机身缓冲装置。该气动式取料机械手具备结构简洁、运行稳定、响应迅速的特点,可实现滚齿加工工件的自动化抓取与转运,有效提升数控滚齿机的自动化生产程度,降低人工干预成本,为齿轮加工生产线的智能化升级提供技术支撑。
关键词:数控滚齿机;取料机械手;气动驱动
In response to the pain points of low production efficiency, insufficient job safety, and high labor intensity in the traditional manual material picking mode of CNC gear hobbing machines, this paper conducts research on the design of the loading and unloading manipulator for CNC gear hobbing machines. The paper systematically reviews the development history and industrial application scenarios of robotic arms, clarifying their basic composition and core design content; Through the scheme demonstration and optimization design of the overall structure of the robotic arm, the coordinate form and degree of freedom configuration suitable for the feeding condition of the gear hobbing machine were determined. The scheme planning of the hand clamping mechanism, wrist rotation mechanism, main and auxiliary arm telescopic mechanism, and body rotation mechanism was completed. At the same time, the pneumatic driving mode and corresponding control scheme were selected, and the main technical parameters of the robotic arm were clarified and its motion logic was analyzed. On this basis, fine structural design and 3D modeling of key components of the robotic arm are carried out. Through theoretical calculations, the hand clamping force, wrist and arm driving torque are verified, and pneumatic components are selected reasonably. The connection structure between each component and the body buffer device are designed. This pneumatic material retrieval robot has the characteristics of simple structure, stable operation, and rapid response. It can achieve automatic grasping and transportation of gear hobbing workpieces, effectively improve the automation production level of CNC gear hobbing machines, reduce manual intervention costs, and provide technical support for the intelligent upgrading of gear machining production lines.
Keywords: CNC Gear Hobbing Machine; Material Retrieval Robotic Arm;Pneumatic Drive;
目录